
Quick Start
What should you do after receiving K1? This tutorial gets you from unboxing to basic robot operation in 5 minutes.
Read Before Operation
- Prepare an open, flat area of at least 2m × 2m for operation.
- During motion, make sure there are no people or obstacles within the robot's operating range to avoid injury or collision.
- During motion, do not touch any part of the robot with your body except the handle.
Step 1 · Unbox
Step 2 · Power On
- Install the battery pack: insert the battery into the robot battery slot with the indicator-light side facing up.
- Press and hold the power button for 3 seconds. Release it after the light turns on. Holding it for more than 6 seconds powers the robot off. After power-on, wait about one minute until the robot plays the prompt sound; the robot can then be controlled remotely.Keep the robot still during this waiting period so that the IMU can initialize.
Step 3 · Operate the Robot
-
Take out the joystick and power it on.
-
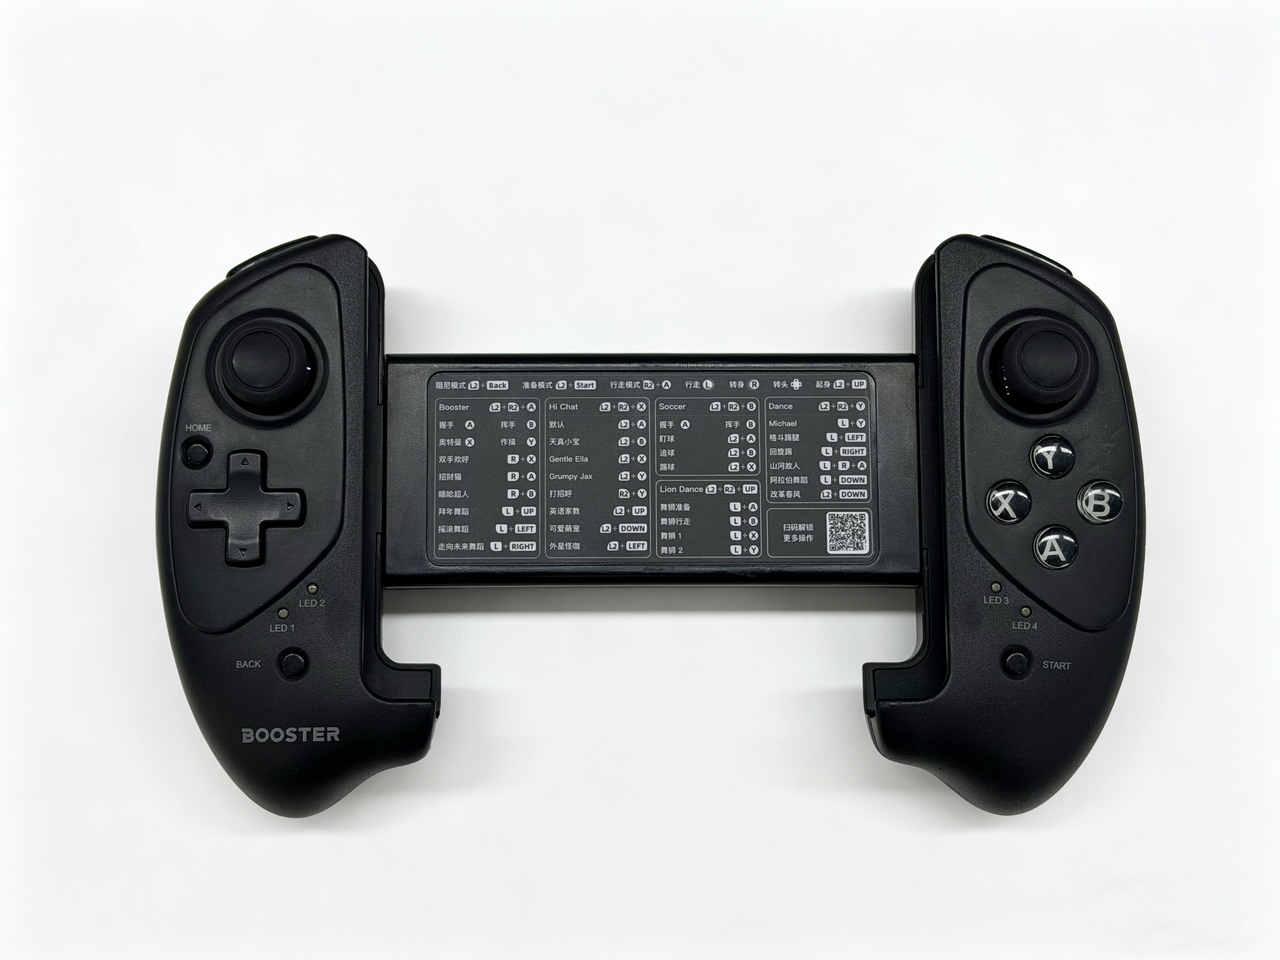
Booster joystick: press and hold the Home button for 5 seconds to power on.
-
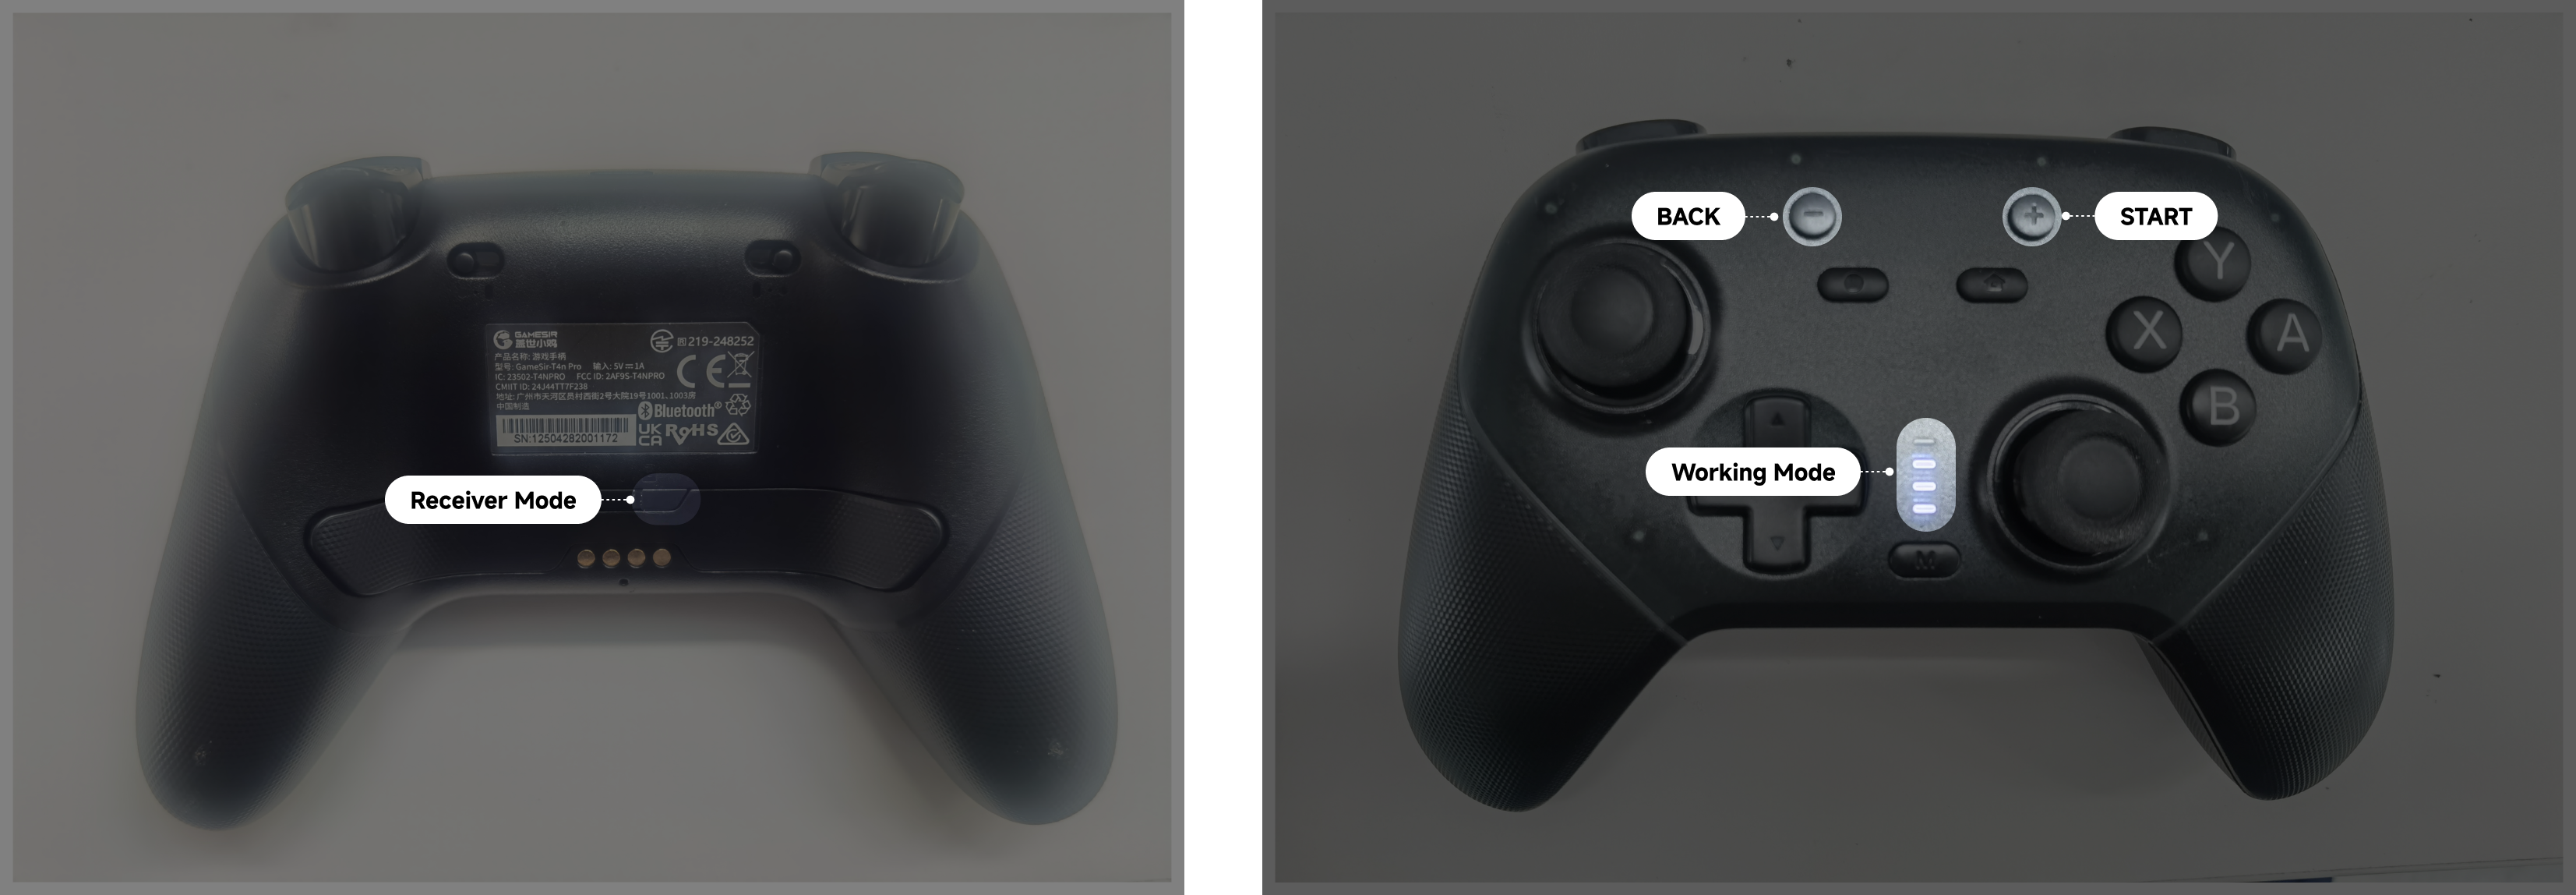
Xbox joystick: before use, confirm that the joystick control mode is receiver mode and that the operating mode shows three lights steadily on.
-
-
Enter PREP mode: Make sure the robot has enough space to straighten its body, then press L2 + Start to enter PREP mode (LT + Start on an Xbox joystick).
-
Stand up automatically: Press L2 + UP to stand up automatically (LT + UP on an Xbox joystick).
-
Omnidirectional walking: After the robot stands up, it automatically enters WALK mode. You can then use the joystick sticks:
- Use the left stick to control walking direction.
- Use the right stick to control turning direction.
- Use the D-pad to control head rotation.
Note: Do not lift the robot in WALK mode. Otherwise, it may fail to detect the ground and kick unpredictably, causing injury.
For more operations, see:Joystick Control
Step 4 · Power Off
- Use L2 + Start on the joystick (LT + Start on an Xbox joystick) to enter PREP mode, then lay the robot flat on the ground
- Press and hold the power button for 3 seconds to power off. After the robot body becomes limp, it can be stored.
- After powering off, wait 6 seconds before powering on again.