
Specifications
Product Specifications
| Type | Specification Parameters | Geek | Education | Professional |
|---|---|---|---|---|
| Basic Parameters | Height (when standing upright) | 0.95m | 0.95m | 0.95m |
| Weight | About 19.5kg | About 19.5kg | About 19.5kg | |
| DoFs | Total DoFs | 22 | 22 | 22 |
| Single Leg DoFs | 6 | 6 | 6 | |
| Single Arm DoFs | 4 | 4 | 4 | |
| Head DoFs | 2 | 2 | 2 | |
| Operational Parameters | Walking Speed | 1.1m/s | 1.1m/s | 1.1m/s |
| Turning Speed | 1.5rad/s | 1.5rad/s | 1.5rad/s | |
| Battery Parameters | Battery Capacity | 2Ah | 5Ah | 5Ah |
| Battery Life | 20min(1.1m/s) | 1h10min(1.1m/s) | 1h10min(1.1m/s) | |
| Charging Time | ≤2h | ≤2h | ≤2h | |
| Cycle Life | ≥500 times | ≥500 times | ≥500 times | |
| Computing Platform | Computing | 48 TOPS (Dense) AI performance | 117 TOPS AI performance | 200 TOPS AI performance |
| Sensors | Camera | Depth Camera | Depth Camera | Depth Camera |
| Microphone | Microphone Array | Microphone Array | Microphone Array | |
| Speaker | 1 | 1 | 1 | |
| Interaction interface | Buttons | Power×1, Interaction*3 | Power×1, Interaction*3 | Power×1, Interaction*3 |
| Indicator Light | RGB LED*1 | RGB LED*1 | RGB LED*1 | |
| Safety Fuction | Auditory Alerts | Low Battery Alert, Joint Overheat Alert | Low Battery Alert, Joint Overheat Alert | Low Battery Alert, Joint Overheat Alert |
| Communication Methods | Wired connection | Gigabit Ethernet | Gigabit Ethernet | Gigabit Ethernet |
| Wireless Connection | WIFI 6 | WIFI 6 | WIFI 6 | |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | |
| Certification Standards | CE/FCC | CE/FCC | CE/FCC | |
| Noise | Walking Noise | ≤70dB | ≤70dB | ≤70dB |
| Environmental Adaptability | Environmental Adaptability | -10℃~45℃ | -10℃~45℃ | -10℃~45℃ |
| Operating Humidity | 5%~90%,without condensation | 5%~90%,without condensation | 5%~90%,without condensation |
Main Components
Joint Motors
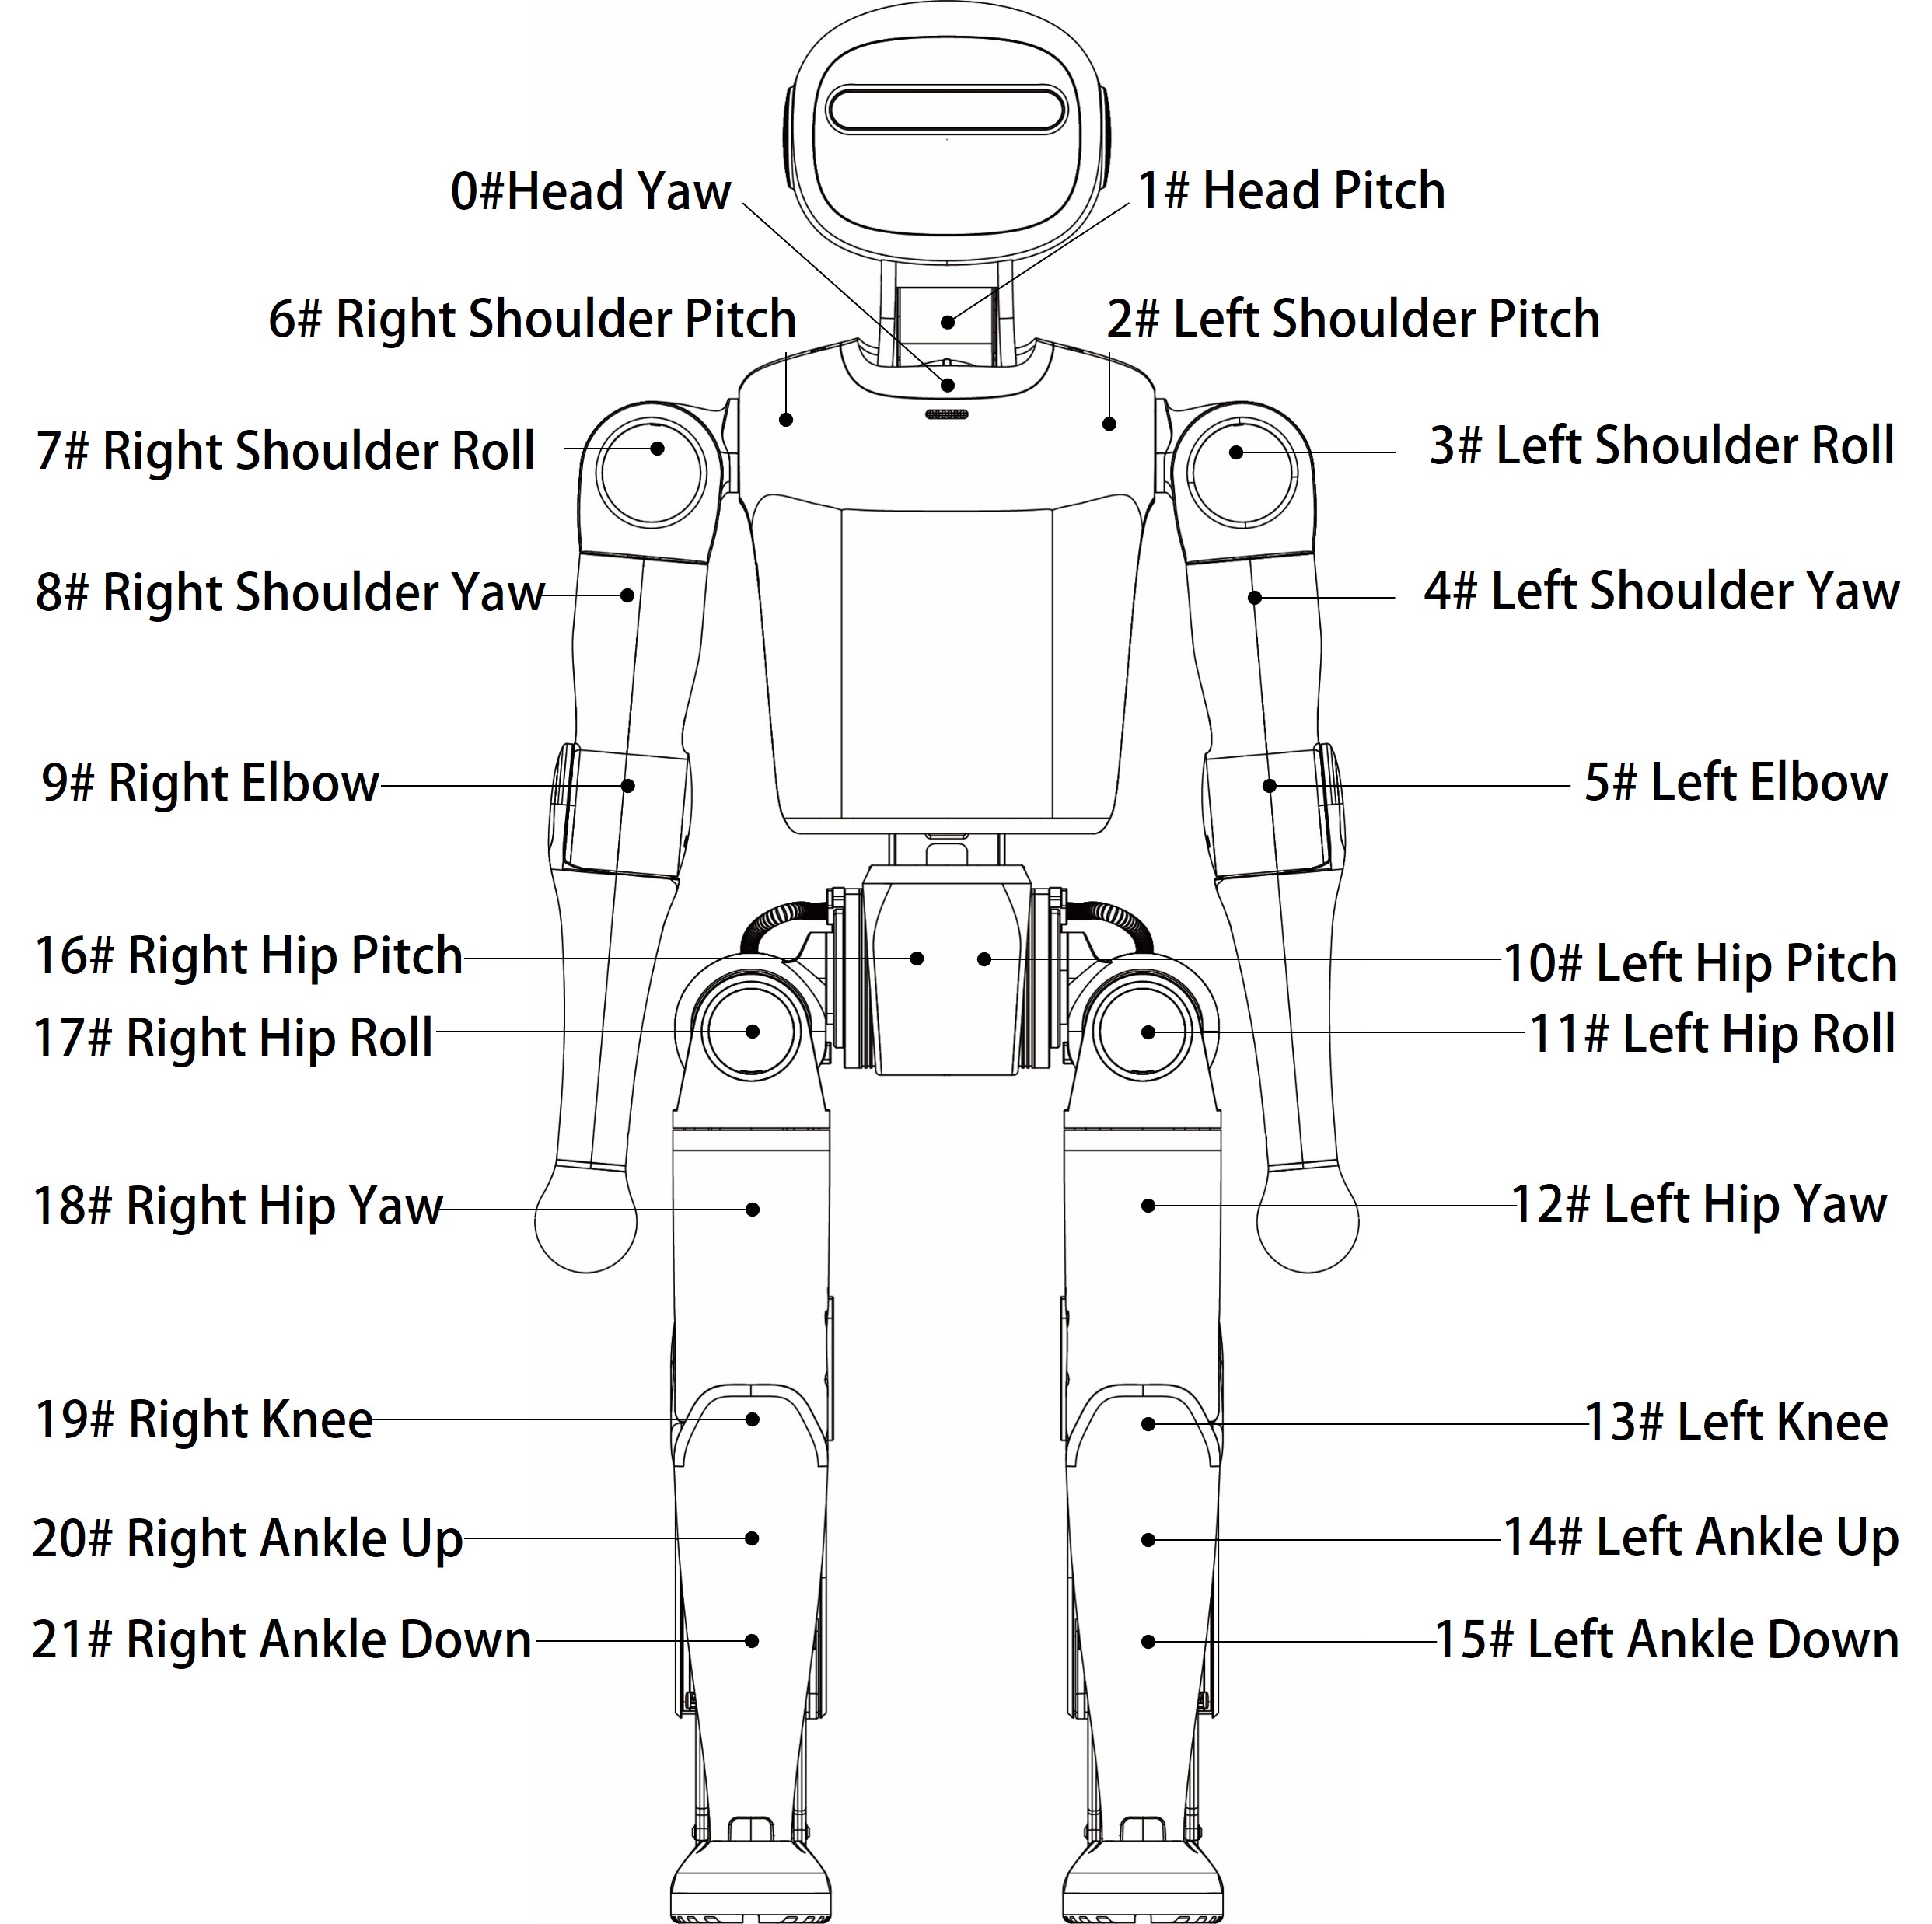
Joint IDs and Limits
| Joint ID | Joint Name | Limit (Degrees) | |
|---|---|---|---|
| Max | Min | ||
| 0 | Head Yaw Joint | 59 | -59 |
| 1 | Head Pitch Joint | 49 | -19 |
| 2 | Left Shoulder Pitch Joint | 69 | -169 |
| 3 | Left Shoulder Roll Joint | 94 | -94 |
| 4 | Left Shoulder Yaw Joint | 109 | -109 |
| 5 | Left Elbow Joint | 39 | -129 |
| 6 | Right Shoulder Pitch Joint | 69 | -169 |
| 7 | Right Shoulder Roll Joint | 94 | -94 |
| 8 | Right Shoulder Yaw Joint | 109 | -109 |
| 9 | Right Elbow Joint | 129 | -39 |
| 10 | Left Hip Pitch Joint | 128 | -170 |
| 11 | Left Hip Roll Joint | 89 | -22 |
| 12 | Left Hip Yaw Joint | 59 | -59 |
| 13 | Left Knee Joint | 133 | 0 |
| 14 | Left Ankle Up Joint | 38 | -17 |
| 15 | Left Ankle Down Joint | 41 | -16 |
| 16 | Right Hip Pitch Joint | 128 | -170 |
| 17 | Right Hip Roll Joint | 22 | -89 |
| 18 | Right Hip Yaw Joint | 59 | -59 |
| 19 | Right Knee Joint | 133 | 0 |
| 20 | Right Ankle Up Joint | 38 | -17 |
| 21 | Right Ankle Down Joint | 41 | -16 |
Coordinate Systems
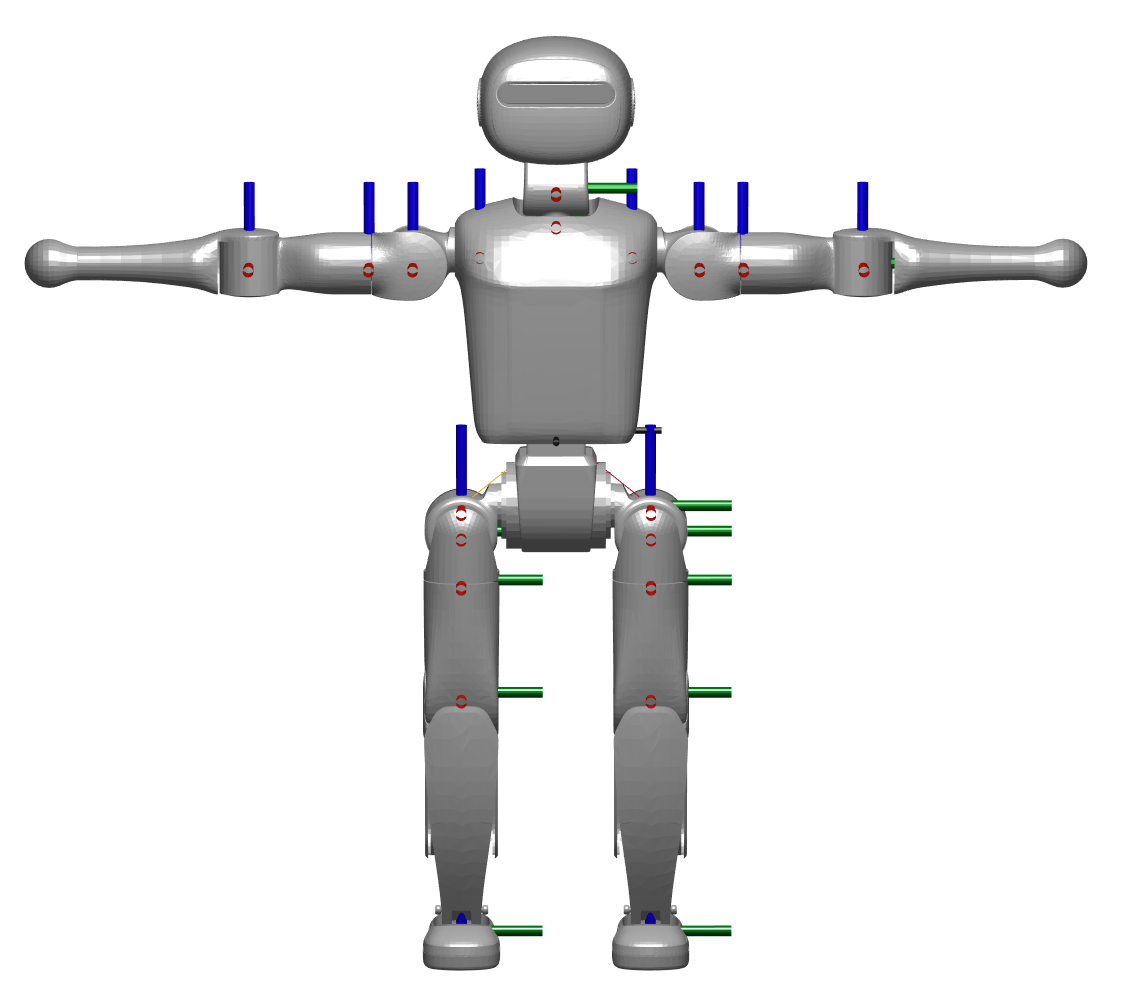
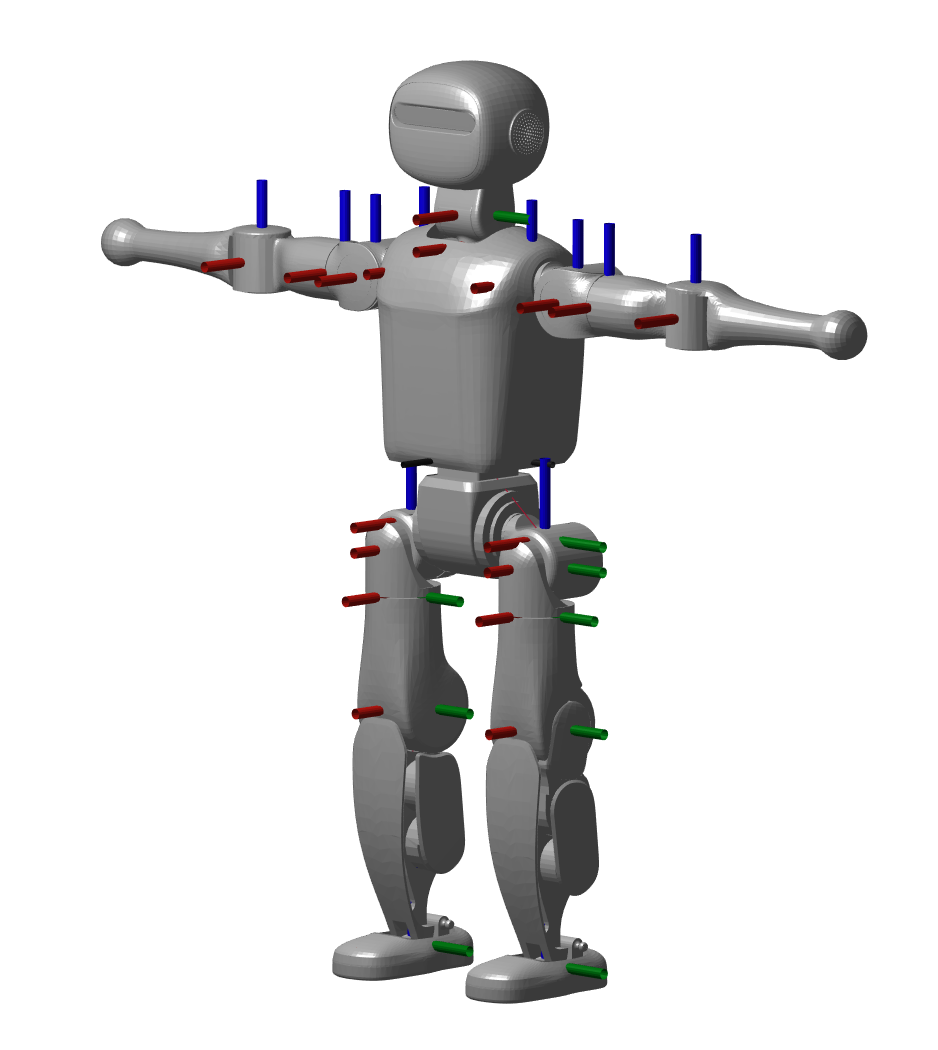
When all joints are at zero degrees, the coordinate systems of the joints are shown below.
Controller
Geek | Education | Professional | |
Processor | High-performance ARM Processor | Jetson Orin NX 8GB | Jetson AGX Orin 32GB |
Computing performance | 1×GoldP@3.2GHz 4×Gold@2.8GHz 3×Silver@2.0GHz 48 TOPS (Dense) | 6-core Cortex-A78AE CPU@2GHz AI performance: 117 TOPS | 8-core Cortex-A78AE CPU@2.2GHz AI performance: 200 TOPS |
Memory | 8GB | 8GB | 32GB |
Storage | 128GB | 512GB | 512GB |
Wired Network | 1000M*1 | 1000M*1 | 1000M*1 |
Wireless Network | Wi-Fi 6*1 | WIFI6*1 | Wi-Fi 6*1 |
Audio | Microphone, speaker | Microphone, speaker | Microphone, speaker |